
 Image 1 of 1
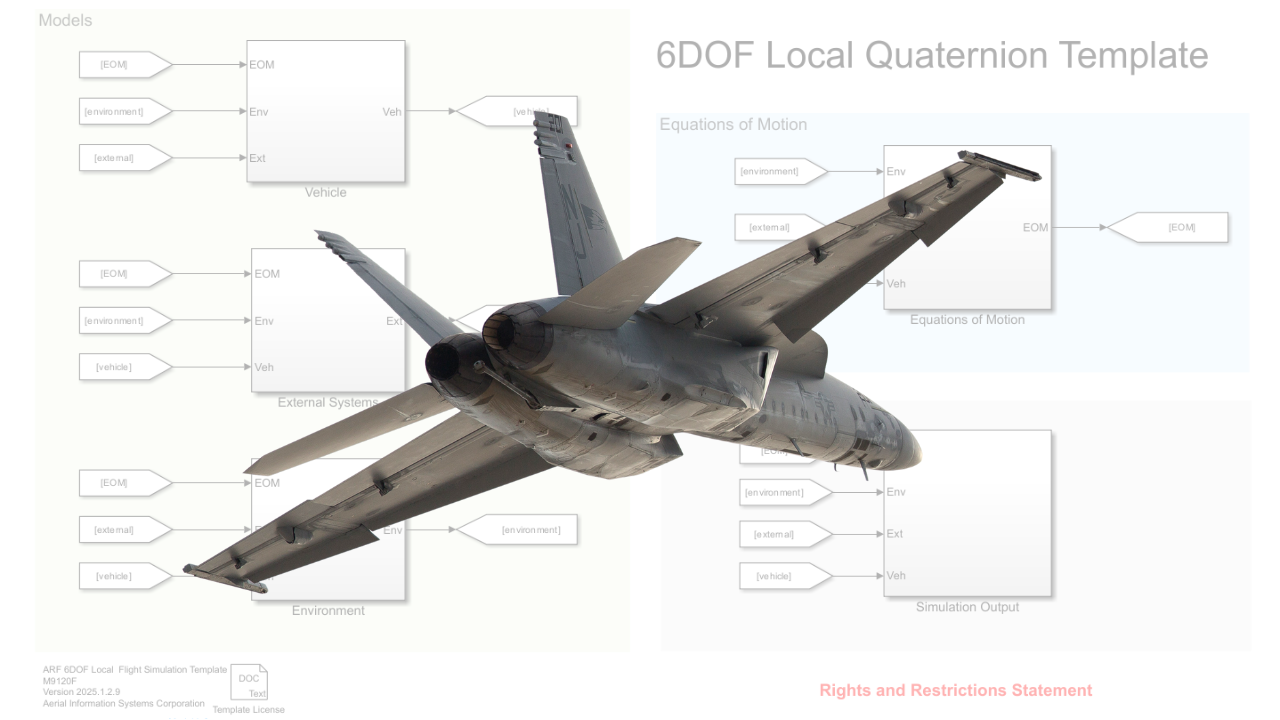
Based on the Basic Flight Simulation Template, this ARF template is tailored for 6DOF equations of motion in a local, flat Earth system. It employs a quaternion mechanization for singularity-free attitude calculations. It is 100% dependency free from any additional Mathworks or 3rd party libraries.
Based on the Basic Flight Simulation Template, this ARF template is tailored for 6DOF equations of motion in a local, flat Earth system. It employs a quaternion mechanization for singularity-free attitude calculations. It is 100% dependency free from any additional Mathworks or 3rd party libraries.